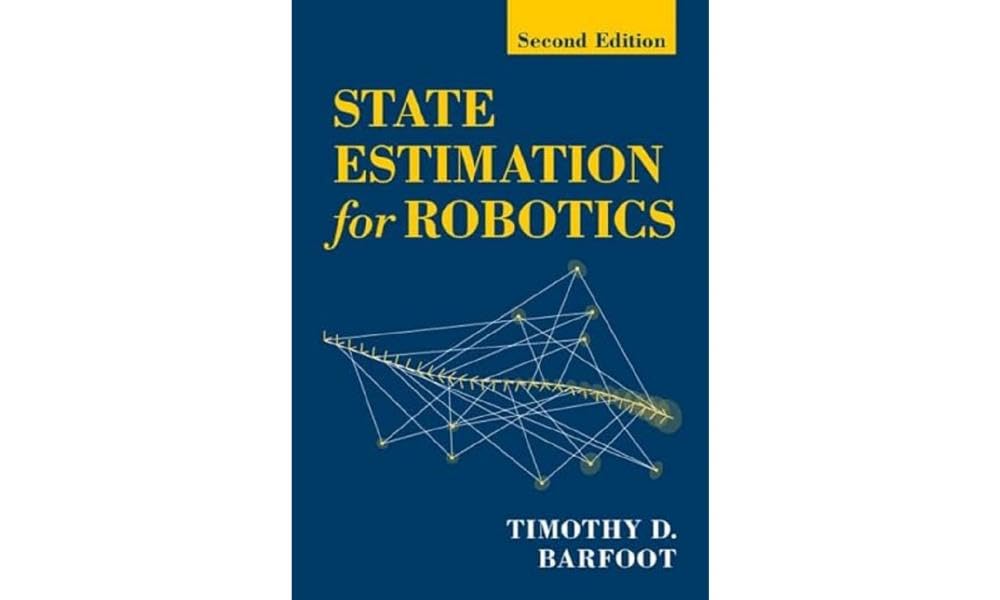
capítulo por capítulo baixar State Estimation for Robotics: Second Edition
por Timothy D Barfoot
State Estimation for Robotics: Second Edition
A key aspect of robotics today is estimating the state (e.g., position and orientation) of a robot, based on noisy sensor data. This book targets students and practitioners of robotics by presenting classical state estimation methods (e.g., the Kalman filter) but also important modern topics such as batch estimation, Bayes filter, sigmapoint and particle filters, robust estimation for outlier rejection, and continuous-time trajectory estimation and its connection to Gaussian-process regression. Since most robots operate in a three-dimensional world, common sensor models (e.g., camera, laser rangefinder) are provided followed by practical advice on how to carry out state estimation for rotational state variables. The book covers robotic applications such as point-cloud alignment, pose-graph relaxation, bundle adjustment, and simultaneous localization and mapping. Highlights of this expanded second edition include a new chapter on variational inference, a new section on inertial navigation, more introductory material on probability, and a primer on matrix calculus.
Procurando State Estimation for Robotics: Second Edition? Aqui você encontra tudo sobre este livro de Timothy D Barfoot, publicado por Cambridge University Press. Nesta página estão a descrição da obra, os detalhes da edição (530 páginas) e os formatos disponíveis para baixar: pdf, ibook, epub, kindle. Se você gosta de Livros Internacionais, Engenharia e Transporte, Engenharia, Mecânica, Robótica, explore também outros títulos da mesma categoria no Porto do livro Português. Veja ainda as outras obras de Timothy D Barfoot em nosso catálogo.
Autores populares
Icon Group International (285) Publishing lmgdaw (262) Nikolay Krechet (164) Kennie B Journals (112) Riddler Books (98) Charles Nehme (95) webmarbook design (95) Mint and Cherry Notebooks (79) Iwona Makara (76) Mary Hirose (75) NAK Legal Publishing (74) Jillo Trukudo (73) Just Visualize It (69) Quick Witted Coconut (67) Talor Press (67) matlasor Sticker's (64) Miller Sye (63) Moonpeak Library (63) Ondrej Sarek (63) Roggie Clark (63)Principais publicadores
Forgotten Books Independently published Routledge Cambridge University Press Dover Publications CRC Press Taschen Princeton University Press Wiley Oxford University Press Springer Kessinger Publishing Thames & Hudson Gale, U.S. Supreme Court Records Bloomsbury Academic O'Reilly Media Rizzoli International Publications Hal Leonard Publishing Corporation Tuttle Publishing Editorial Tirant lo Blanch